

View on GitHub
Open this notebook in GitHub to run it yourself
- This tutorial proposes a novel quantum computing approach to solving the inverse kinematics problem of a robotic arm [1].
- The algorithm is based on variational optimization methods similar to the Variational Quantum Eigensolver (VQE) and the Quantum Approximate Optimization Algorithm (QAOA).
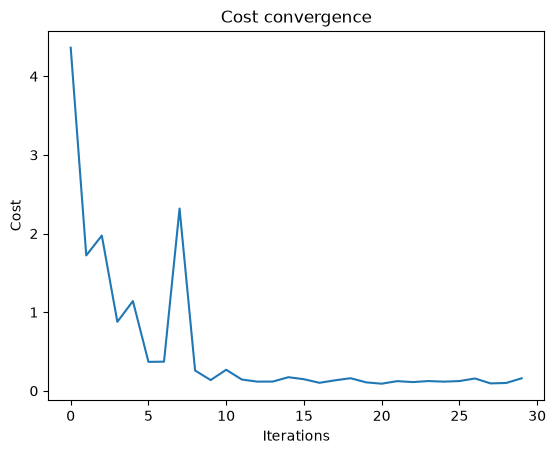
- COBYLA (Constrained Optimization BY Linear Approximation) - evaluates the error and updates the parameters iteratively.
- The proposed quantum circuit ansatz represents each robotic link using one qubit.
Ansatz Circuit Without Entanglement
Output:
Output:
Post Processing
Output:
Create Cost Function
Target positionPauli Based Measurment
Output:
Output:
Output:
Output:
Output:
Output:
Output:
Output:
Output:
Output:
Output:
Output:
Output:
Output:
Output:
Output:
Output:
Output:
Output:
Output:
Define the Function for Extracting the Predicted Position from the Quantum Algorithm Results
Output:
Output: